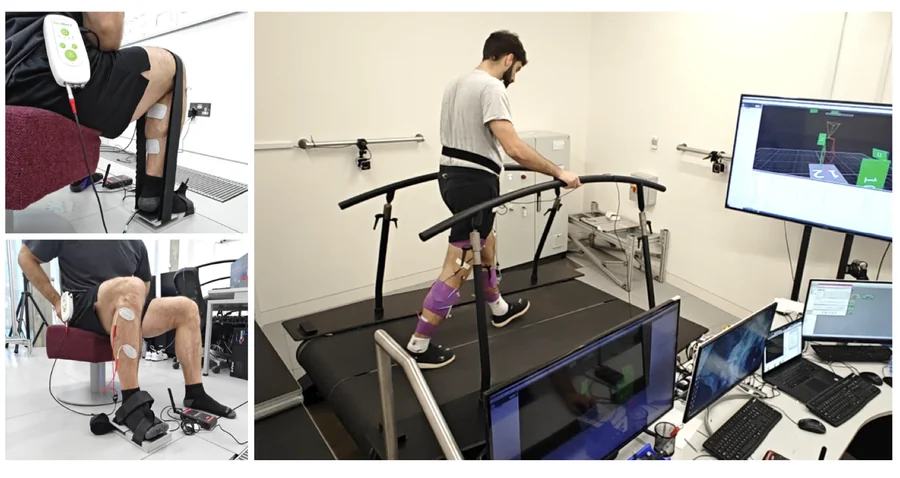
BIBE 2025
Assist-As-Needed Control for FES in Foot Drop Management
A. Christou, E. Lister, G. Andreopoulou, D. Mahad, S. Vijayakumar
PhD Candidate · The University of Edinburgh
I work on the deployability of wearable robotics — exoskeletons and assistive devices — for people living with neurological conditions. My aim is practical, effective systems that improve mobility and quality of life.
About
Most wearable robots work in the lab. Very few survive contact with a person's actual life.
I'm a PhD candidate at The University of Edinburgh, part of the UKRI AI CDT-D²AIR programme, working within the SLMC Group and supervised by Prof. Sethu Vijayakumar.
I work on the next generation of soft wearable robots and assistive technologies for healthcare, with a focus on translating them from the lab into real use. That means addressing the barriers to adoption directly: textile-based hardware that integrates with the body, adaptive AI controllers that cope with unstructured environments, and the wearability questions — comfort, donning, durability — that decide whether a device is actually kept on.
My background spans computer science, engineering and the natural sciences, so my interests cover both the design of soft actuators and the intelligent systems that control them.
If you'd like to collaborate, or just want to know more, do get in touch.
Publications
A. Christou, E. Lister, G. Andreopoulou, D. Mahad, S. Vijayakumar
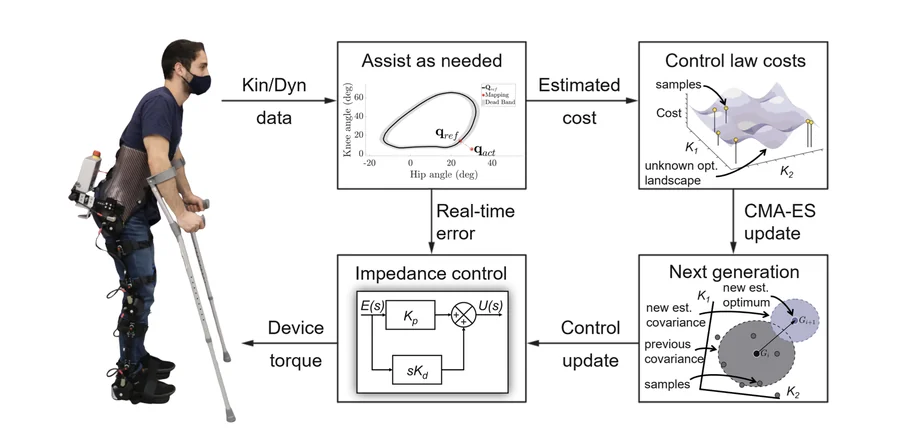
A. Christou, A. Sochopoulos, E. Lister, S. Vijayakumar
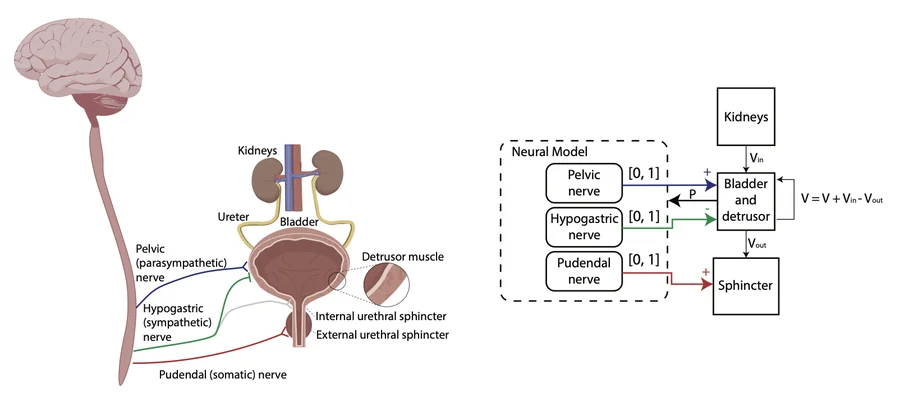
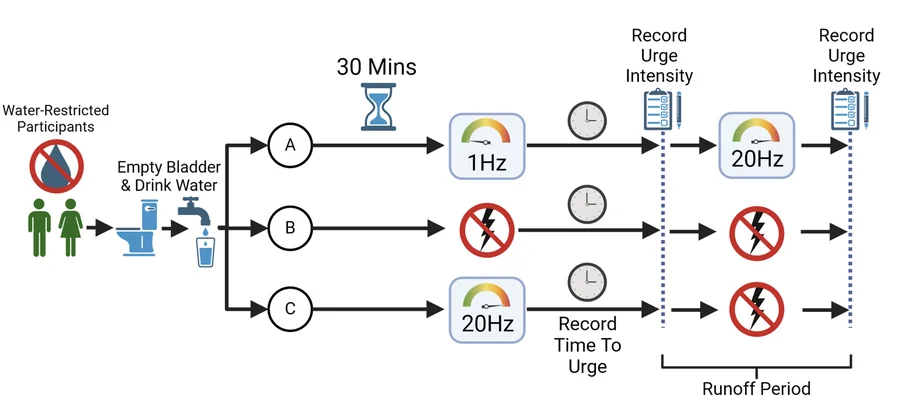
A. McConnell-Trevillion, M. Jabbari, W. Ju, E. Lister, A. Erfanian, S. Mitra, K. Nazarpour